
Sensor fusion in MATLAB
sftools is a MATLAB toolbox for students learning estimation, filtering, and sensor fusion. It favors explicit workflows: you define the models, write the filtering loop, and inspect its estimates and uncertainty.
The toolbox provides state containers, dynamic and observation models, least-squares estimators, Kalman and particle filters, nonlinear moment transforms, analysis, and plotting.
A tracking example
A constant-velocity Kalman filter tracks a simulated target from noisy position measurements. The plot shows the true path, measurements, estimate, and selected 95% confidence ellipses.
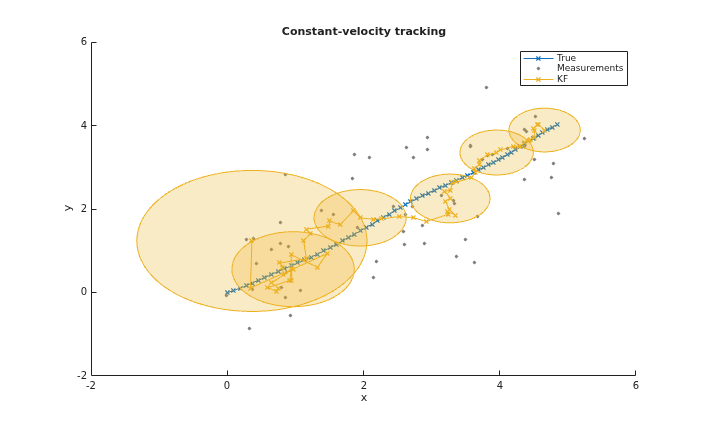
Explore a similar tracking example in the documentation.
Start here
- Download the installable MATLAB toolbox (.mltbx) — requires MATLAB R2025a or newer.
- Getting started — add the toolbox to the MATLAB path and run a first estimate.
- Documentation — explore the models, estimation and filtering interfaces.
- Example manual (PDF) — worked examples, plots, and practice exercises.